
Six Ultrasonic Weld Modes and When to Use Each
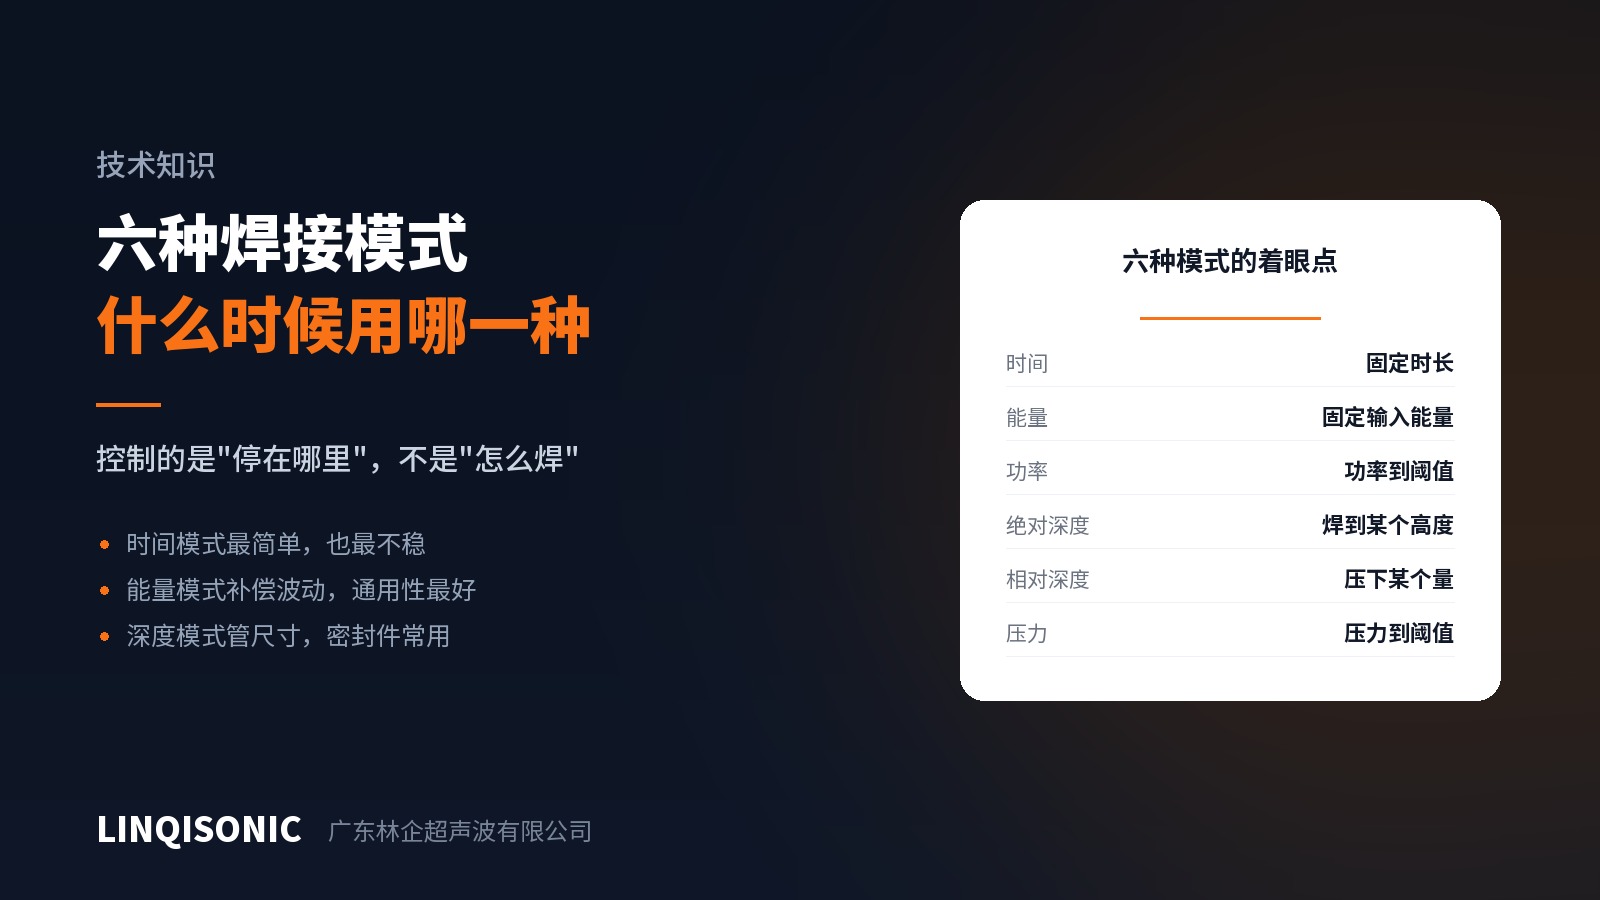
Ultrasonic welders typically offer six weld modes: time, energy, power, absolute depth, relative depth and force. What they control is not how the weld is made but the condition on which welding stops. Choose wrongly and the same machine performs markedly worse.
Time mode
Set a weld duration; the machine stops when it elapses. The simplest to set up.
The problem is that it compensates for nothing. Thinner incoming material, slightly lower air pressure, a little horn wear — the energy actually reaching the interface changes, yet the machine still welds for the set time. In volume production, time mode is usually the first thing to cause yield problems.
Suits: simple parts, stable incoming material, undemanding tolerances — or early trials to find a working range.
Energy mode
Set a weld energy; the machine stops when cumulative input reaches it.
This is the most generally useful mode. Because it watches how much energy goes in, small variations in material or conditions are absorbed by automatically lengthening or shortening the cycle. For most applications the default should be energy mode, not time mode.
Power mode
Stops when weld power reaches a threshold. Power reflects instantaneous load and rises then falls during the weld — climbing as melting begins, falling as the melt layer changes the impedance.
Suits: cases where a particular melt state must be caught, or as a secondary criterion alongside another mode.
Absolute and relative depth
These control dimensions directly and are the usual choice for seals and dimensionally sensitive assemblies.
Absolute depth — stop at a defined overall height. It controls finished height, suiting assemblies with a height tolerance.
Relative depth — from the contact point, travel a set distance and stop. It controls how much material is melted away, suiting cases where the fused volume itself matters.
The difference is the datum. Absolute depth references the machine's fixed origin, so incoming height tolerance transfers entirely into weld depth. Relative depth references the actual contact point on each part, absorbing incoming height variation. Where incoming height varies, relative depth is more dependable.
Force mode
Stops when weld force reaches a set value. Less common, used mainly where the final clamping state is specified.
Choosing
A practical order:
Finished dimension has a tolerance → depth mode first, relative depth if incoming height varies;
Fused volume must be consistent and dimensions are not critical → energy mode;
Trial stage, finding a range → time mode, then switch to energy or depth;
Production → whichever mode is used, set monitoring limits on the other dimensions as well.
That last point matters most. Welding in energy mode, still monitor post-weld depth; welding in depth mode, still monitor energy. Controlling and judging on a single dimension surrenders the ability to detect faults — a fully fused part and a crushed one can share the same final height while differing greatly in energy.
Modes and monitoring dimensions by machine are on the ultrasonic welding machine pages. Send part drawings and tolerances to 1427498429@qq.com, or call +86 769 8202 9510 / +86 137 6001 0932.